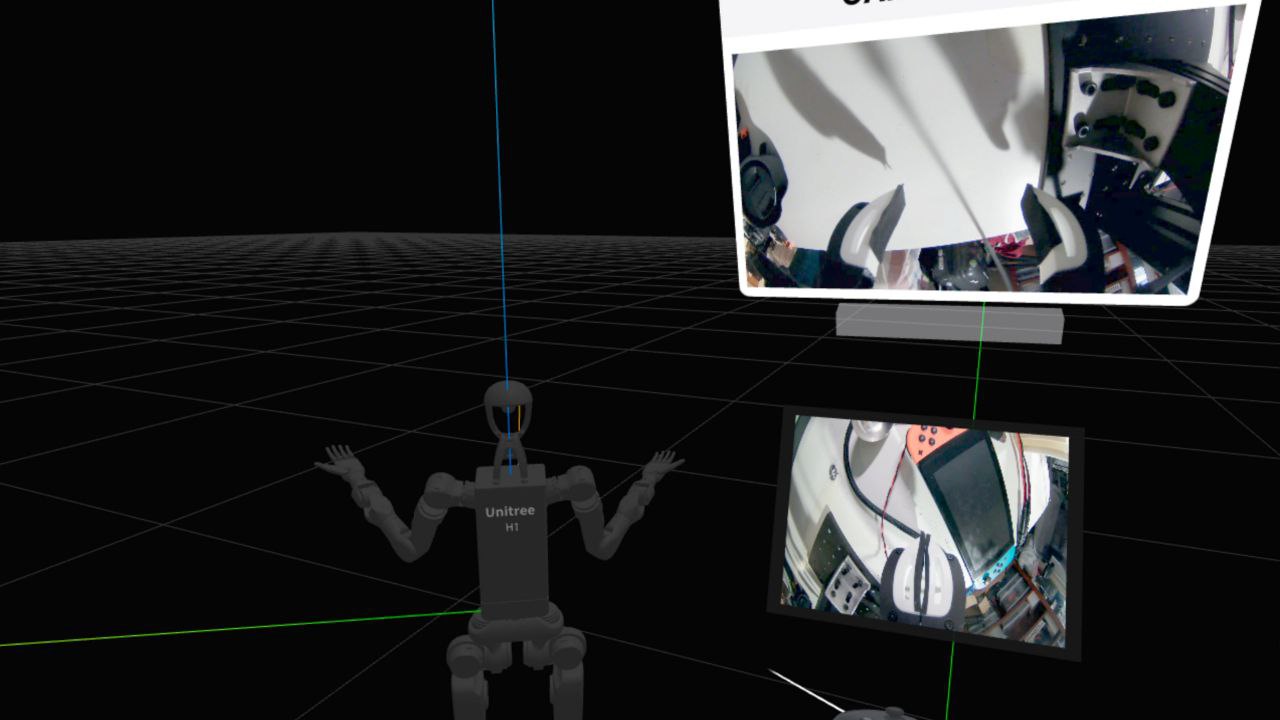
XR teleoperation
TeleopXR
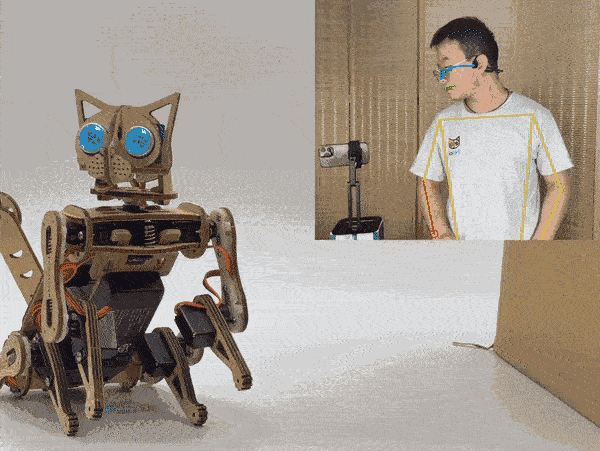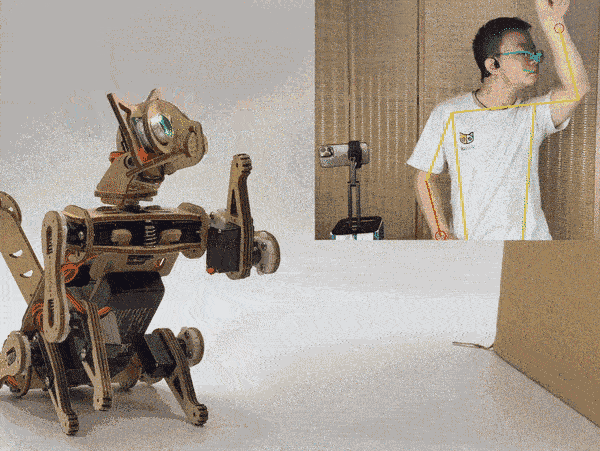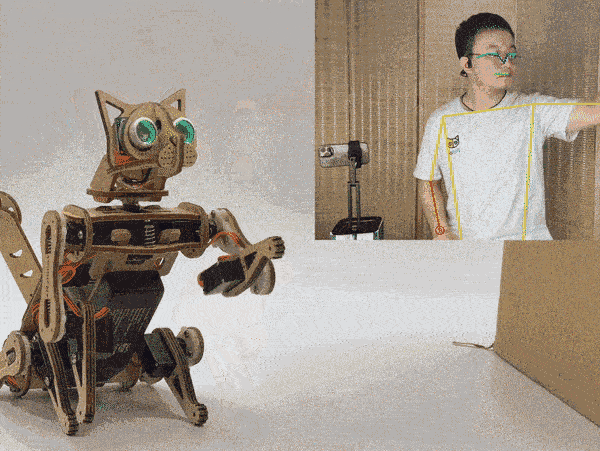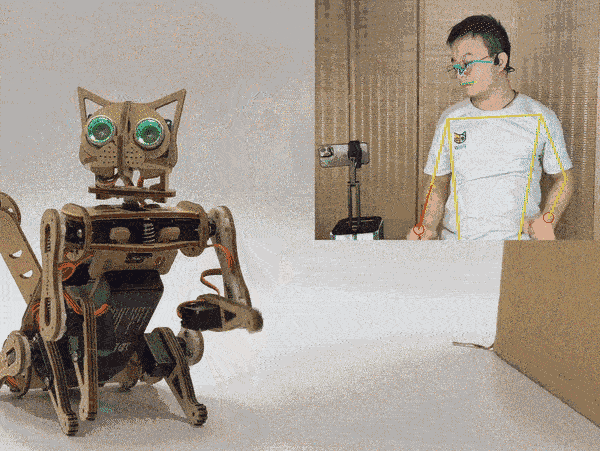
WebXR robot teleoperation with live video, robot-model visualization and inverse-kinematics control from an XR interface.
Screenshot from the TeleopXR project.
Explore projectRobotics / Projects
Personal projects in robotics, hardware and developer tools.
XR teleoperation
WebXR robot teleoperation with live video, robot-model visualization and inverse-kinematics control from an XR interface.
Screenshot from the TeleopXR project.
Explore projectCAD / robot models
Convert Onshape CAD assemblies into configurable Xacro/URDF robot descriptions, with meshes, joint definitions and runtime joint-transform overrides for robot simulation and integration.
Explore projectMotor control / in development
A Rust library with Python bindings for controlling Damiao-family motors over CAN, including motor commands, feedback and USB-to-CAN connections.
Explore projectHardware / robot design
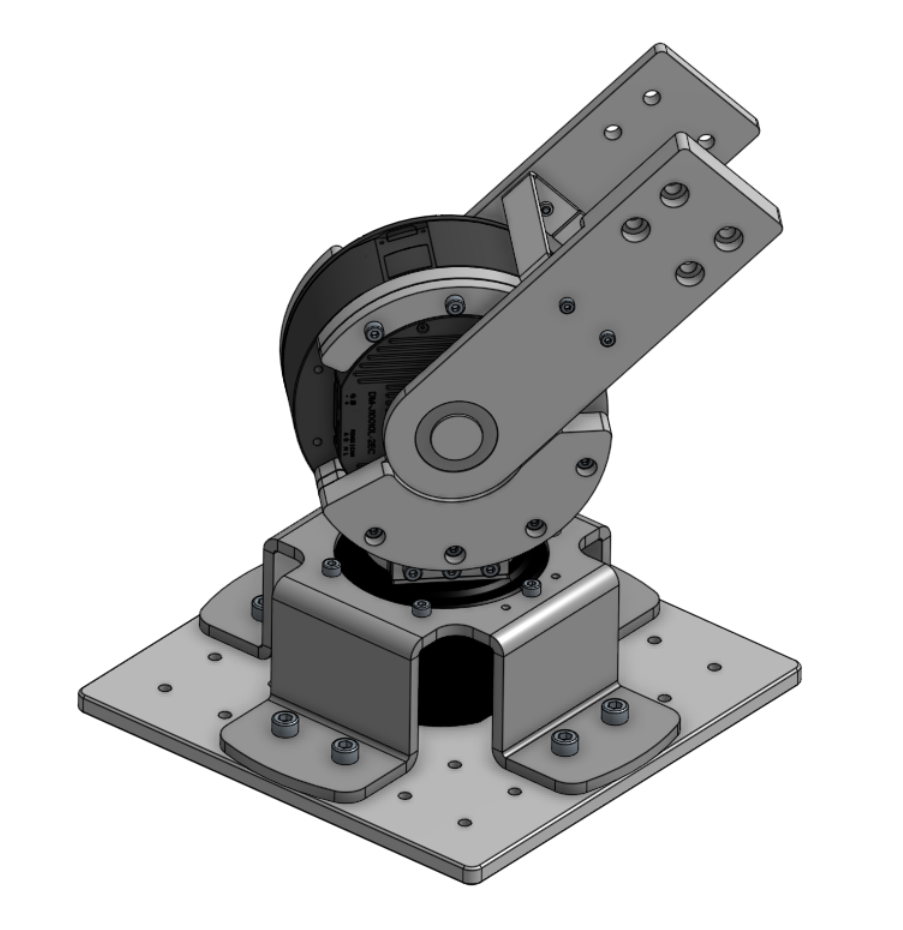
A waist extension for OpenArm that adds a rotating base to the arm assembly, with CAD files, a bill of materials and an integrated robot description.
Assembly image from the project repository.
Explore projectDeveloper tools / Rust
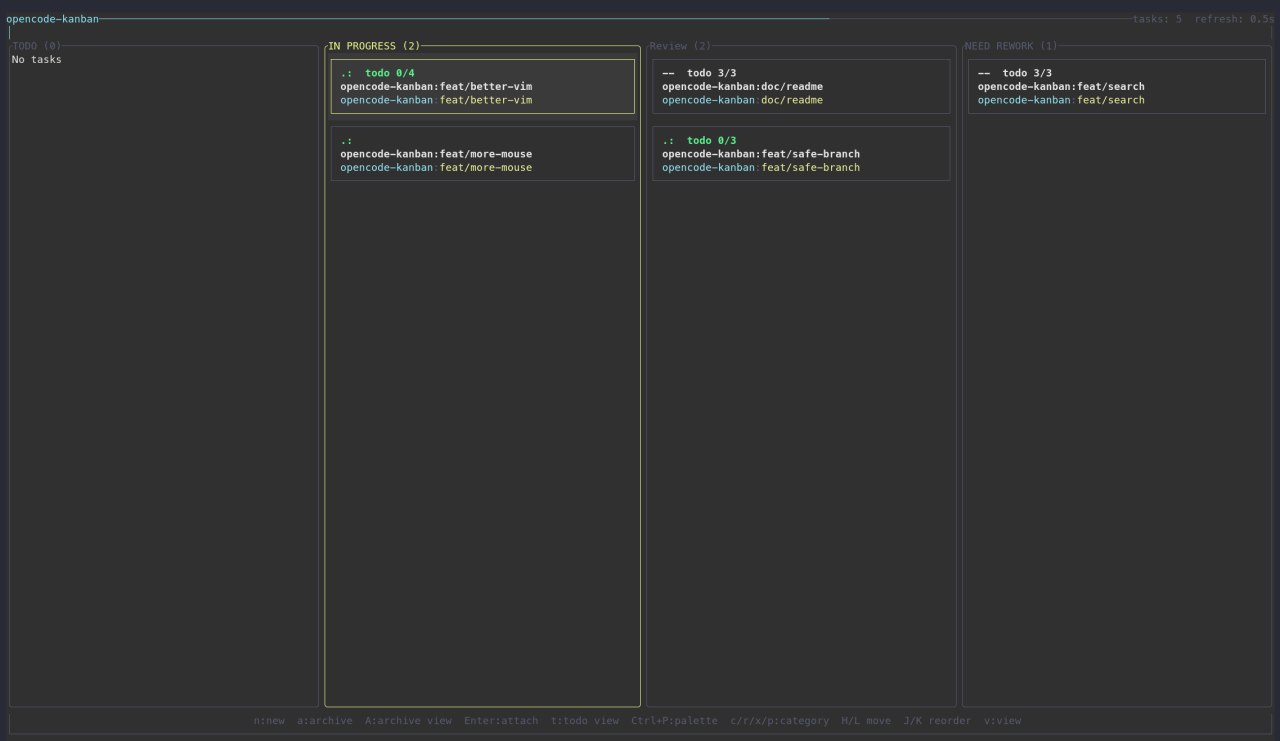
A terminal kanban board that organizes coding tasks alongside Git worktrees and OpenCode tmux sessions.
Board screenshot from the project README.
Explore projectDeveloper tools / ROS 2
A Linux ROS 2 Humble workspace template that combines Pixi environments, uv Python packages and colcon build tasks to help start ROS projects.
Explore project2023 / Robotics project
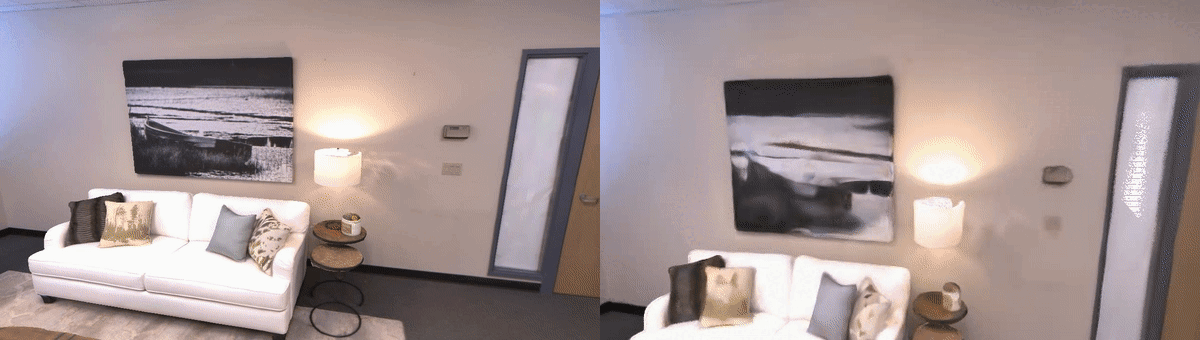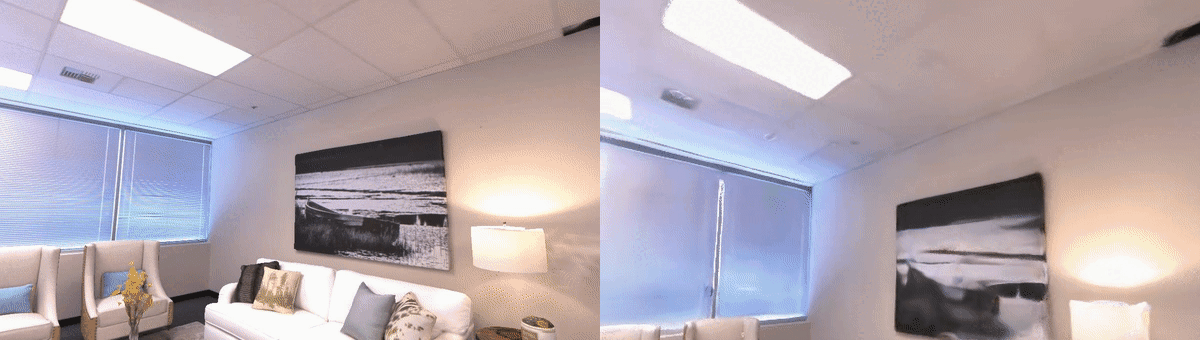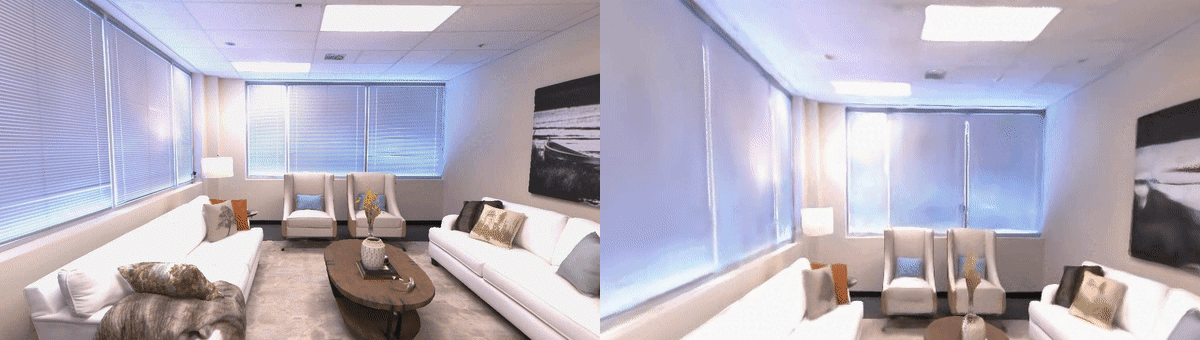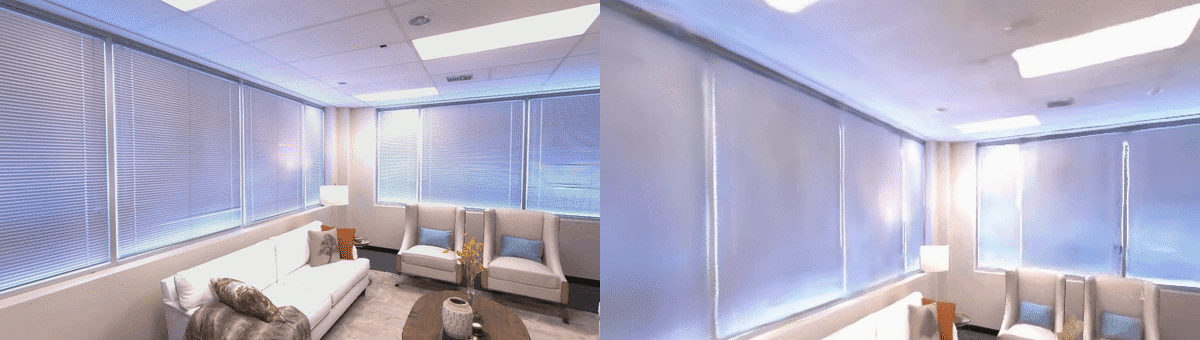
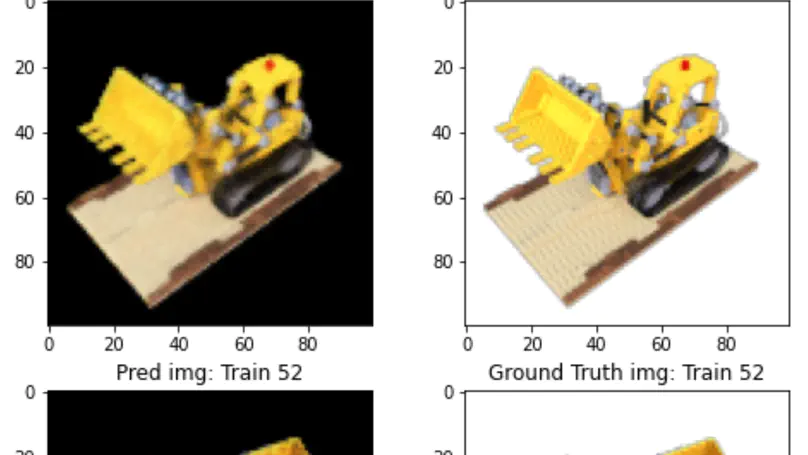
Achieve illumination robustness for Vox-Fusion, a NeRF-based SLAM project. Course Project for ROB 530 Mobile Robotics W23.
Explore project2022 / Robotics project
A course mini project for EECS 498 - Deep learning for Computer Vision 2022
Explore project2021 / Robotics project
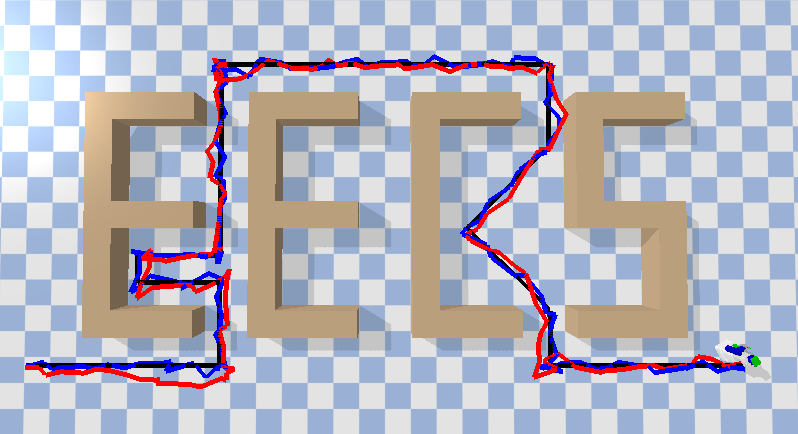
Implements a kalman filter and a particle filter and compares their accuracy using pybullet as simulation environment.
Explore project